At Flipside AI (a wholly-owned subsidiary of Nexscient), we believe the next era of intelligence isn’t just about code; it’s about human data. We are engineering the human data foundation required to take robots out of the lab and into our lives. To do that, we need real human demonstrations of how the world actually works.
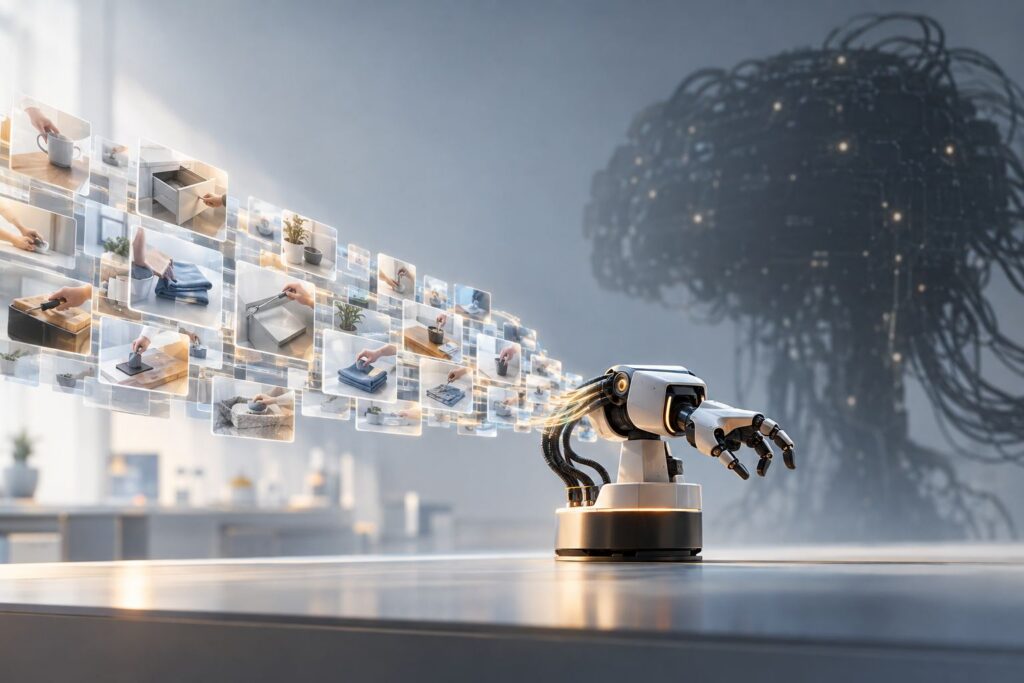
TaskAlpha™ makes your everyday chores lessons for supervised training of humanoid robots. Each task includes clear instructions, camera guidance, and examples so your submission is usable in learning. Real environments and real routines are what make the data valuable. Record your chore videos, upload them using the app or website, and get paid.
Empowering everyday people to earn money by recording household tasks that become supervised training data for humanoid robots.
Foundational Human Intelligence for Machines
Humanoid robots require real-world, human demonstrations to learn how tasks are performed. We capture this “alpha layer” of intelligence, the authentic human behavior that cannot be scraped, simulated, or synthetically generated to form the foundation of physical AI learning.
Contributor-Powered, Paid Platform
TaskAlpha enables individuals to record guided, chore-based demonstration videos using standardized capture protocols. Approved submissions are compensated, creating a scalable global contributor network that transforms ordinary household activity into valuable training data for humanoid robots.
Training-Ready Data Infrastructure — Not a Marketplace
Every submission passes through structured task design, human supervision, annotation, enrichment, and multi-stage quality assurance, resulting in quality training-ready datasets engineered for supervised training, imitation learning, and Vision-Language-Action (VLA) pipelines.